Robotics · Mechanical Design · Team Lead · 2024–Present
Project Rover — Rocker-Bogie Drivetrain
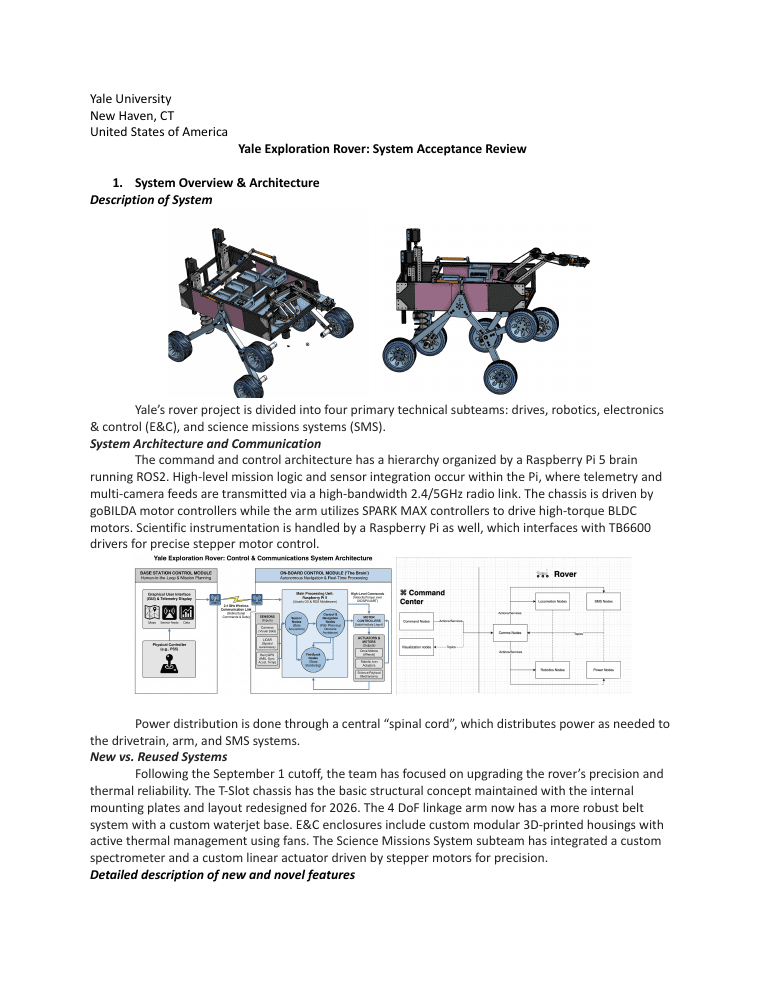
As Drives subteam lead, deliver the chassis, suspension, and drivetrain for a University Rover Challenge rover that can clear the rough field terrain of the competition course.

- Lead a 10-student Drives subteam, owning the rocker-bogie drivetrain and the interfaces where other subteams' mechanisms integrate into the main chassis.
- Designed and machined a rocker-bogie suspension using aluminum linkages, plates, and mounts to keep the wheels planted while clearing obstacles in field conditions.
- Selected tread geometry, motors, and gearboxes, and used FEA to size mounts for the expected operating loads.
- Drove subteam process and schedule: concise design/test briefs, GD&T drawing checklists and tolerance analysis, purchase lists, and assembly/test procedures.
SolidWorks CAD with FEA and load analysis; hands-on CNC machining and 3D printing of structural components; GD&T and tolerance analysis throughout.
SolidWorksFEAGD&TCNC3D PrintingLoad Analysis
- Designed and built the structural components for a custom rocker-bogie suspension and integrated them into the competition chassis.
- Integrated motors and treads and validated the drivetrain on terrain and obstacle testing, which is an ongoing 2024–present effort.
The Yale Exploration Rover system review covering architecture, integration and testing, project management, budget, and the science plan for the 2026 University Rover Challenge.
 Open full report ↗


